Yifan Kang

I’m a junior at MIT, double-majoring in Artificial Intelligence (Course 6-4) and Mathematics (Course 18). I’m advised by Leslie Kaelbling in the Learning & Intelligent Systems Group.
Robots deployed in the real world encounter novel environments and unseen tasks beyond their training distribution, often leading to policy failures. I want to build robots that can turn these experiences into new capabilities—not just execute what they learned during training. My research asks how robots can adapt after deployment: infer useful structure from a few demonstrations, diagnose failures through interaction, and revise their behavior without collecting large datasets or retraining from scratch.
Currently, I’m working on robot-use agents that improve their policies from demonstrations. In ENCORE, I explored how a coding agent can use demonstrations directly in context to generate executable manipulation programs and refine them through execution feedback. In KeyFlow, I explored how an agent can optimize a non-parametric flow field constructed from a few demonstrations by revising the keypoints and retrieval programs that define it.
Outside the lab, I enjoy long-distance running, watching anime, rhythm games (Arcaea and Maimai), and singing.
Selected research all →
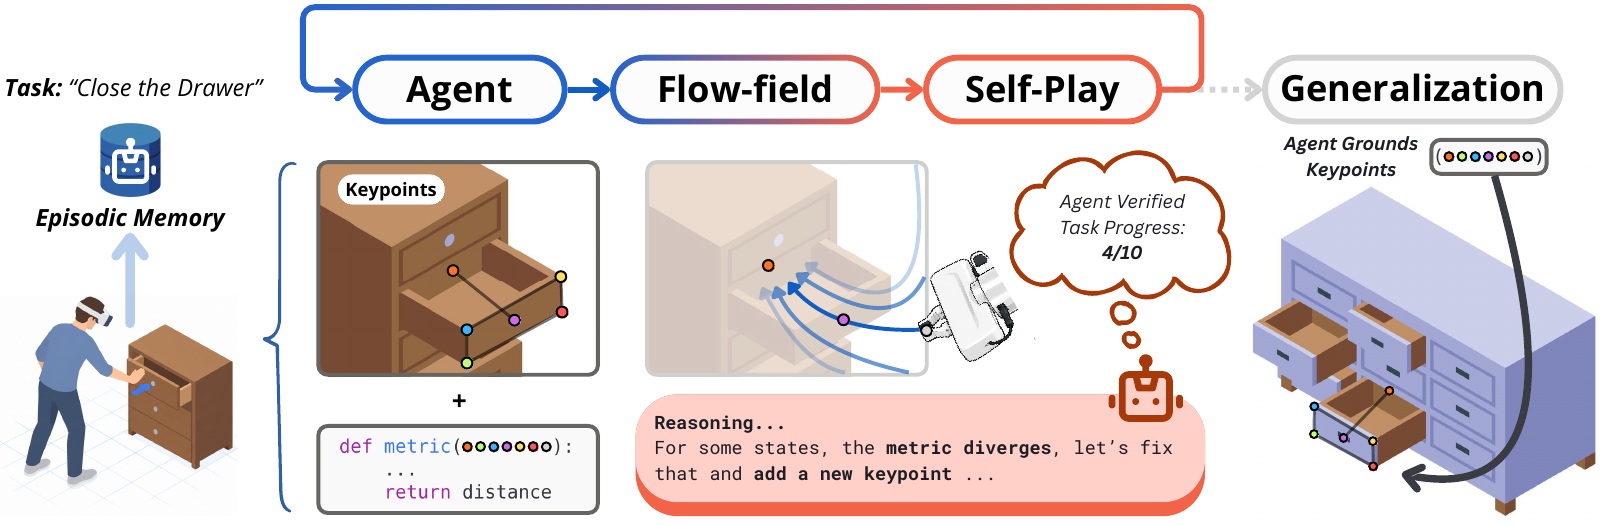
KeyFlow: Agentic Policy Adaptation with Episodic Memory
CoRL 2026 Workshop Learn@Deploy
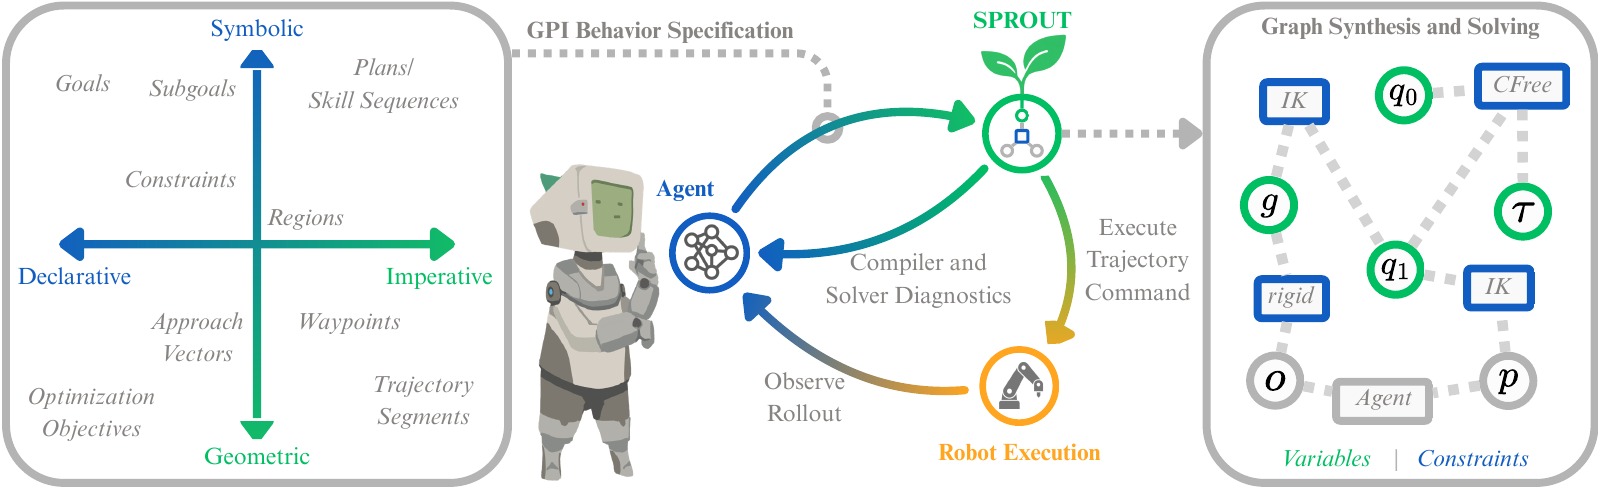
Generalized Planning Interfaces for Agentic Robotics
CoRL 2026 Workshop on Agentic Robotics
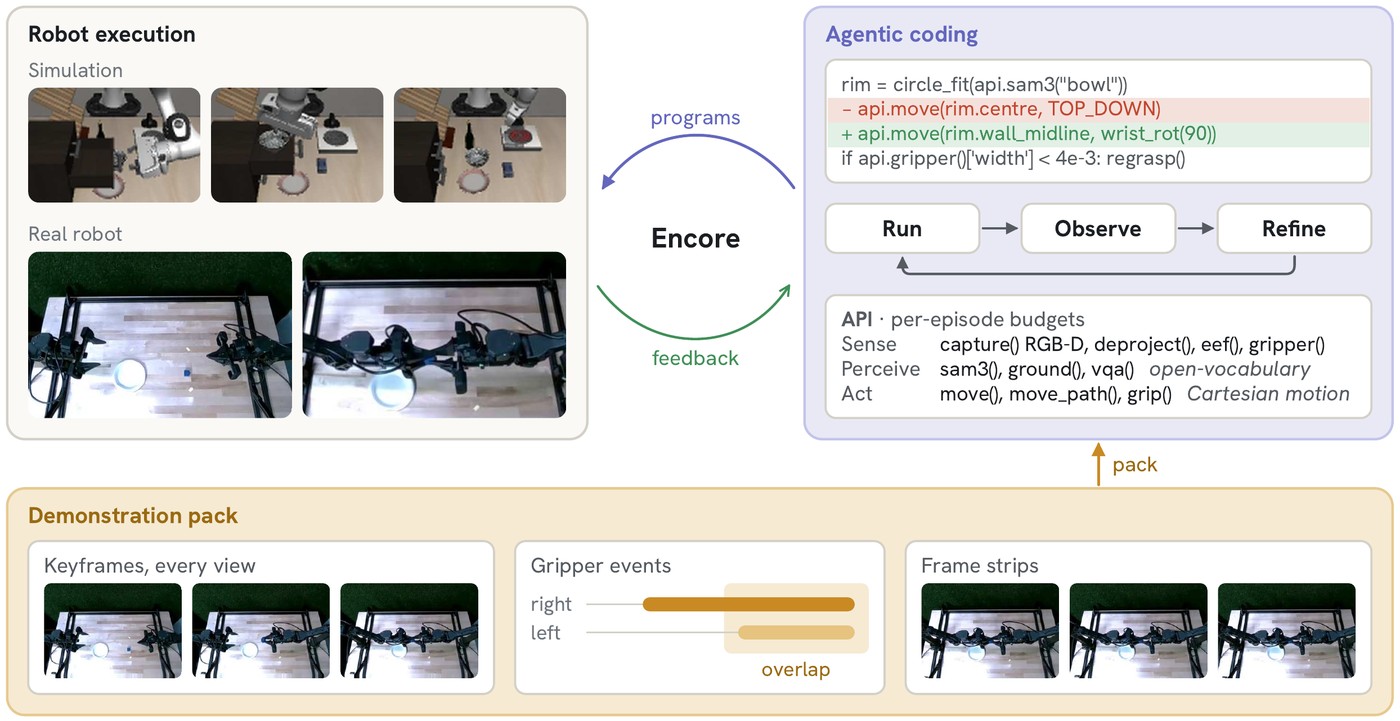
ENCORE: Few-Shot Agentic Discovery of Manipulation Strategies
NeurIPS 2026 Robot Learning Workshop (Oral, 6/43) · CoRL 2026 Workshop on Agentic Robotics
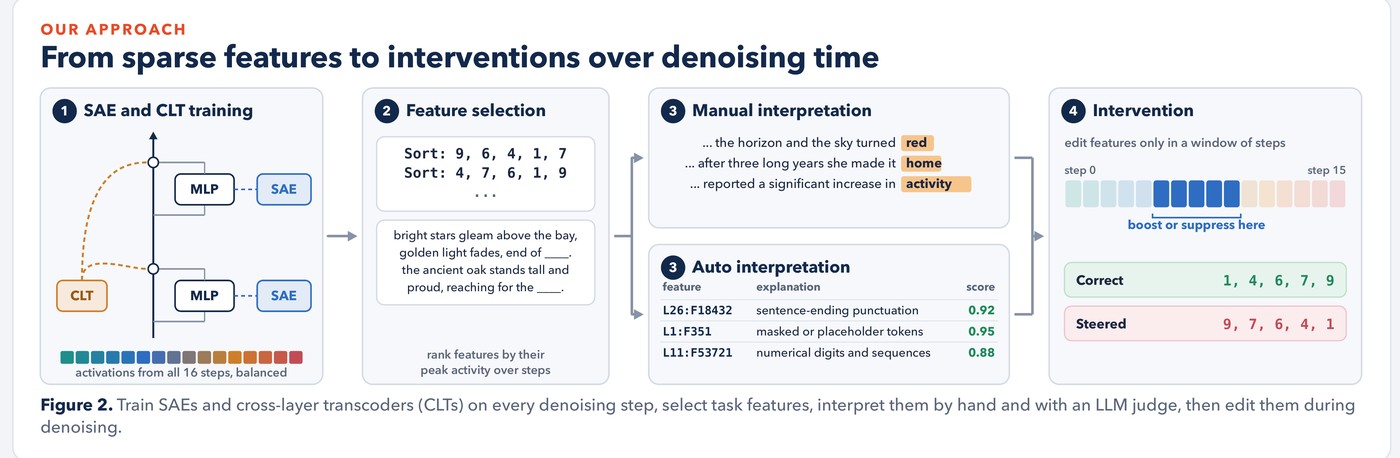
Interpreting Diffusion Language Models Over Denoising Time
CoLM 2026 Workshop on Non-Autoregressive Language Models
[Poster]
Doodle Agent: Exploring Freeform Visual Generation with Multimodal LLMs
ICCV 2025 Workshop on AI for Visual Arts (AI4VA)
[Website]
Experience
- Research Intern, 2077AI — Jun 2026 to present
- Student Researcher, MIT, with Leslie Pack Kaelbling — Jun 2025 to present
- Student Researcher, MIT, with Antonio Torralba — summer 2025
Elsewhere
- Writing — course surveys, final projects and lecture notes.
- Coursework — what I have taken at MIT, by term.
Latest posts all →
| May 28, 2026 | Sutton's Big World Hypothesis |
|---|---|
| Feb 07, 2026 | Classes that I am taking this semester (Spring 2026) |
| Feb 02, 2026 | The Alchemist’s Shadow in a Chemist’s World |